DIY Robotics
Crafting Tomorrow's Tech with Today's Budget
Discover the art of building a robotic hand using everyday materials and open-source platforms.
Though building a robotic hand on a budget might seem futuristic, with the right resources and some creativity, it becomes entirely feasible. By utilizing affordable technologies such as 3D printing and microcontrollers like Arduino, you can assemble an impressive piece of technology without spending a fortune.
Chapter 01
Choosing Cost-Effective Materials
The foundation of building a budget-friendly robotic hand lies in selecting the right materials.
Harnessing the Potential of 3D Printing
3D printing has transformed various sectors, and robotics is no different. With materials like PLA and ABS plastic, you can produce the necessary parts for your robotic hand. Not only are these materials cost-effective, but they also offer essential durability.
- PLA: Known for being easy to print and biodegradable, PLA is a favorite among beginners.
- ABS: Offers enhanced strength and flexibility, making it suitable for parts that need extra robustness.
Controlling Movement with Servos and Microcontrollers
Your robotic hand’s movement is governed by servos and microcontrollers. Small servos are affordable and adequate for this purpose. An Arduino board acts as the command center, managing inputs and outputs to animate your robotic hand.
By utilizing affordable technologies such as 3D printing and microcontrollers like Arduino, you can assemble an impressive piece of technology without spending a fortune.
A robotics enthusiast
Chapter 02
Programming Your Robotic Hand
Bringing motion to your creation with basic programming skills.
Preparing Your Arduino Environment
To animate your robotic hand, configuring your Arduino setup is essential. This involves installing the Arduino IDE and establishing connections with your board.
int servoPin = 9;
Servo myServo;

void setup() {
  myServo.attach(servoPin);
}

void loop() {
  myServo.write(0);
  delay(1000);
  myServo.write(180);
  delay(1000);
}
Introduction to Basic Motion Control
Programming the movement of your robotic hand entails writing a simple script to manipulate the servos. By altering angles in the code, you can emulate the hand’s opening and closing functions.
- Initialize the servo: Connect the servo to a digital pin.
- Define movements: Use
myServo.write()functions to adjust the angles.
Narrative flow
Scroll through the argument
01
Step 1: Design Your Parts
Use CAD software to design each component of the hand.
02
Step 2: Print and Assemble
3D print each part and assemble them with screws and glue.
03
Step 3: Program the Motions
Upload your code to the Arduino and test the hand's movements.
Chapter 03
Testing and Iteration
The final steps involve testing your creation and refining its performance.
Pursuing Continuous Improvement
Testing is critical to the success of your robotic hand. Begin with basic tasks and progressively program more intricate sequences. Anticipate some trial and error as you refine the hand’s functionality.
Robotic Hand Development Stages
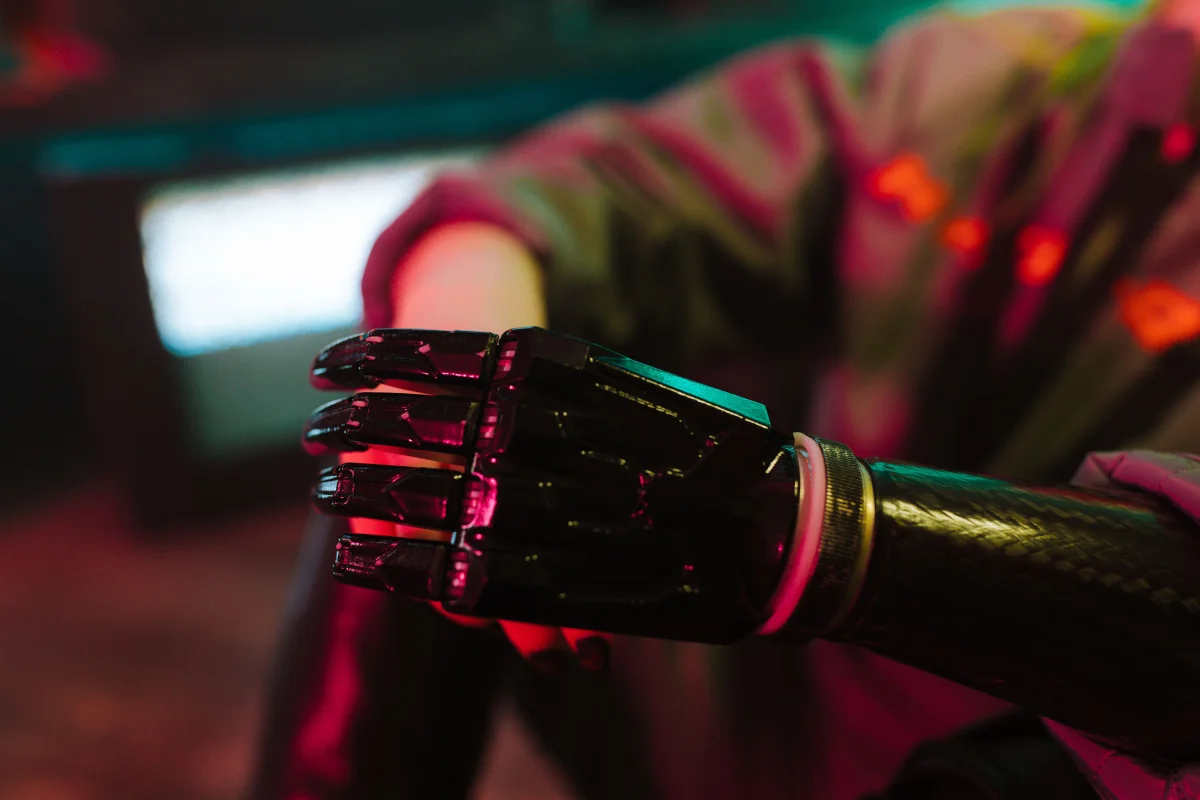
Navigating and Overcoming Challenges
Creating a robotic hand presents its share of challenges. Components might not align perfectly, or movements may not be as seamless as anticipated. Patience and persistence remain your staunch allies.
Embarking on the journey to create a budget-friendly robotic hand is both educational and rewarding. By marrying technology with creativity, you can accomplish impressive feats without significant expenses. Every prototype sharpens your skills and inspires future ingenious ideas.